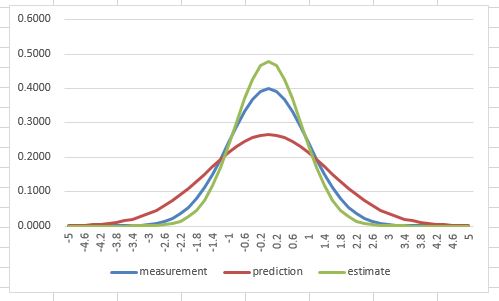
From the point of view of the measurement, we can make a prediction of the measurement ${\textbf{z}_1}'$ from ${\textbf{x}_1}'$, and we can get $({\textbf{z}_1}', \textbf{H}_1{\textbf{P}_1}'\textbf{H}_1^T)$.
The measurement is $(\textbf{z}_1, \textbf{R}_1)$, the estimate is
$\textbf{z}_1^* = (\textbf{I}-\textbf{G}_1){\textbf{z}_1}'+\textbf{G}_1\textbf{z}_1$
a good estimate comes with
$\textbf{G}_1=\textbf{H}_1{\textbf{P}_1}'\textbf{H}_1^T(\textbf{H}_1{\textbf{P}_1}'\textbf{H}_1^T+\textbf{R}_1)^{-1} = \textbf{H}_1\textbf{K}_1$
$\textbf{z}_1^* = (\textbf{I}-\textbf{H}_1\textbf{K}_1)\textbf{H}_1{\textbf{x}_1}'+\textbf{H}_1\textbf{K}_1\textbf{z}_1$
$ = \textbf{H}_1(\textbf{I}-\textbf{K}_1\textbf{H}_1){\textbf{x}_1}'+\textbf{H}_1\textbf{K}_1\textbf{z}_1$
$\textbf{H}_1\textbf{x}_1^* = \textbf{H}_1(\textbf{I}-\textbf{K}_1\textbf{H}_1){\textbf{x}_1}'+\textbf{H}_1\textbf{K}_1\textbf{z}_1$
so $\textbf{K}_1$ can give a good estimate for $\textbf{z}_1^*$, it seems also imply that
$(\textbf{I}-\textbf{K}_1\textbf{H}_1){\textbf{x}_1}'+\textbf{K}_1\textbf{z}_1$ can give a good estimate for $\textbf{x}_1^*$.